Robots and worlds
Every picture on this page is a real run: the simulator with the robot and world named under it, seen through the viewer. The commands run as they are after installing Lagrange and sourcing the workspace.
Mobile robots (AMR)
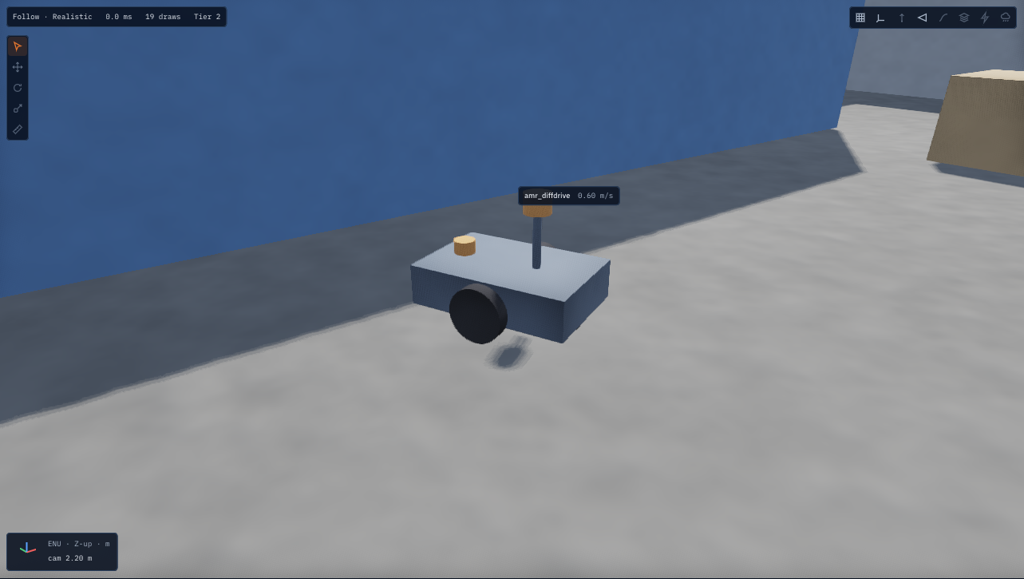
The sample AMR is a differential-drive robot with two lidars, an IMU, two drive motors and a
battery on a 48 V bus. It drives a demo loop round the sample warehouse until /cmd_vel
takes over, and Nav2 can drive it through the warehouse.
lagrange amr
Tutorial: an AMR in a warehouse · Rigid body · Sensors · Motors · Battery
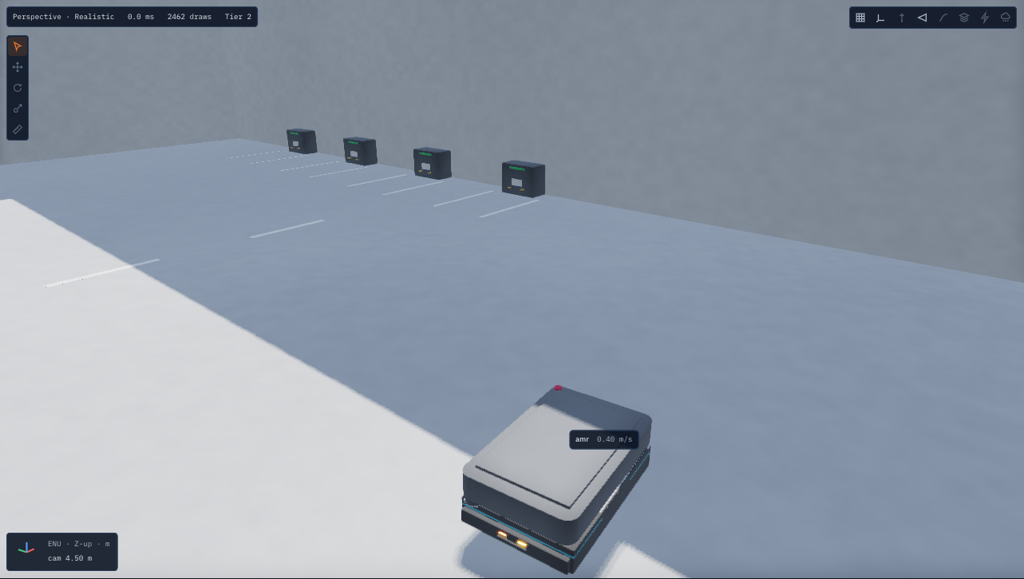
A swerve AMR (AMR_FMS), whose wheels steer on their own, so /cmd_vel with linear.y moves
it sideways. It runs in its own 60 m × 40 m warehouse.
lagrange swerve
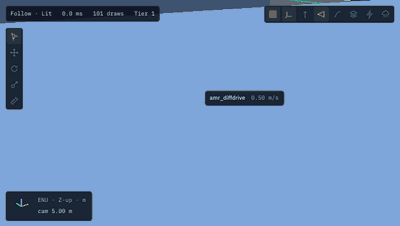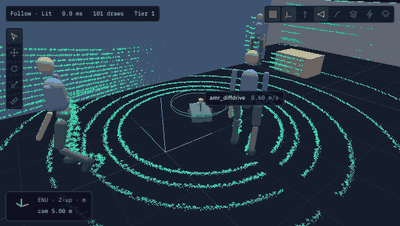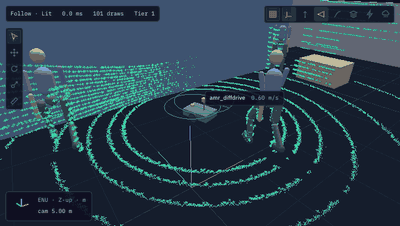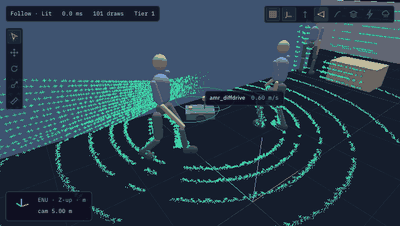
People walk round the robot, step by step, and steer away from it and from each other. The lidars and cameras see them; Tutorial: people around your robot, Humans.
A robot in the sample warehouse
Drones
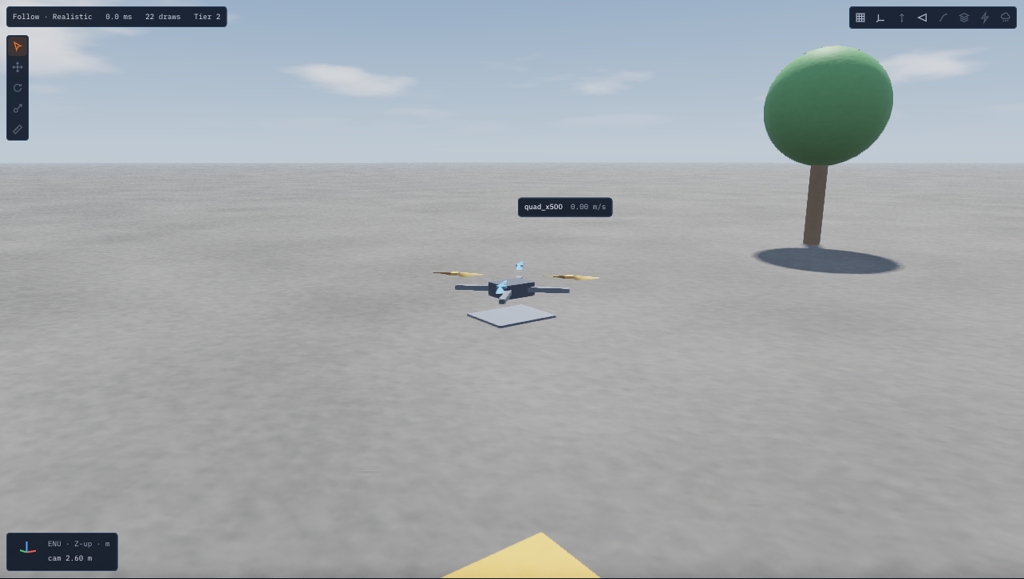
The sample quadcopter (500 mm, four rotors, a 4S battery, an IMU, GNSS, magnetometer and
barometer) takes off and hovers, flies by /cmd_vel, and flies PX4 and ArduPilot missions in
lockstep. Its rotors can be thrust coefficients or blade elements, and its downwash is
computed, fitted or live.
lagrange quad
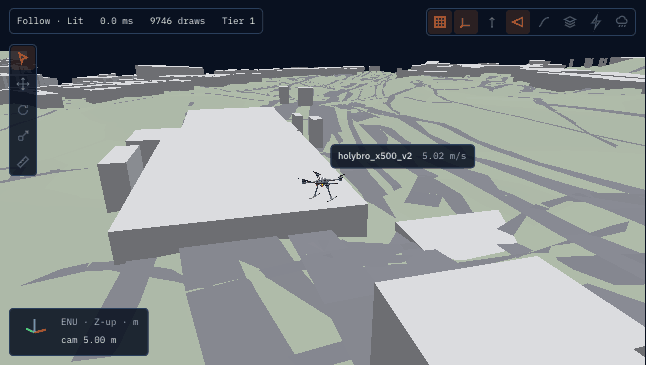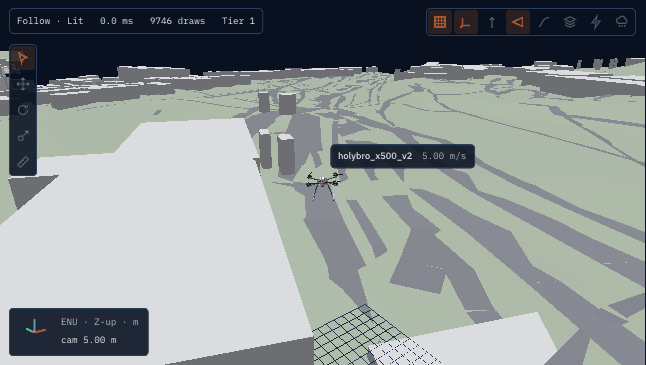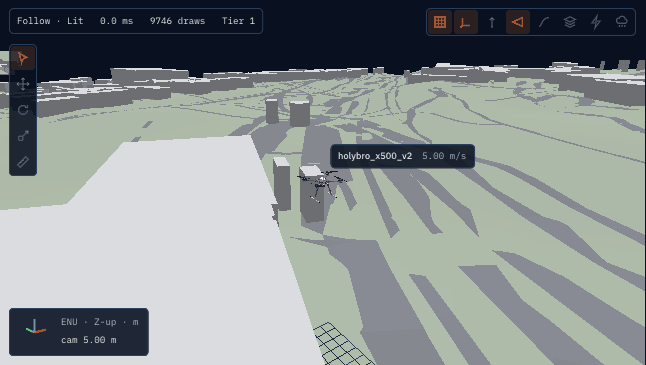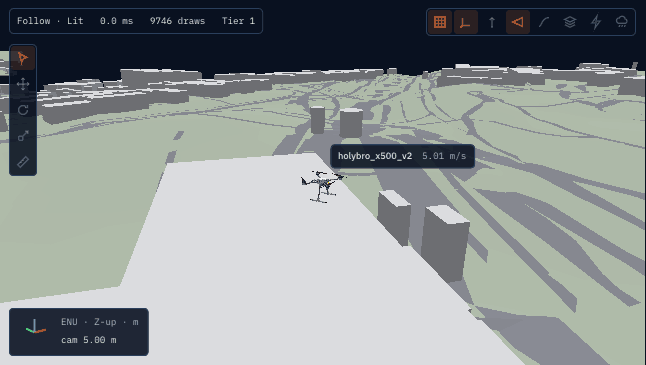
The Holybro X500 V2, PX4’s reference frame, with its real mesh (fetched with
ros2 run lagrange_assets fetch_assets holybro_x500_v2), here over Zurich, a world built from
the Copernicus elevation model and OpenStreetMap.
The air under a hovering quadcopter: particles and its speed through the drone, then in wind
Beside a 12 m building and over its roof
Live air: a lattice Boltzmann box round the drone, on the GPU
Tutorial: a quadcopter · Test your own drone · Rotors · Downwash · Weather
Cars and autonomous cars
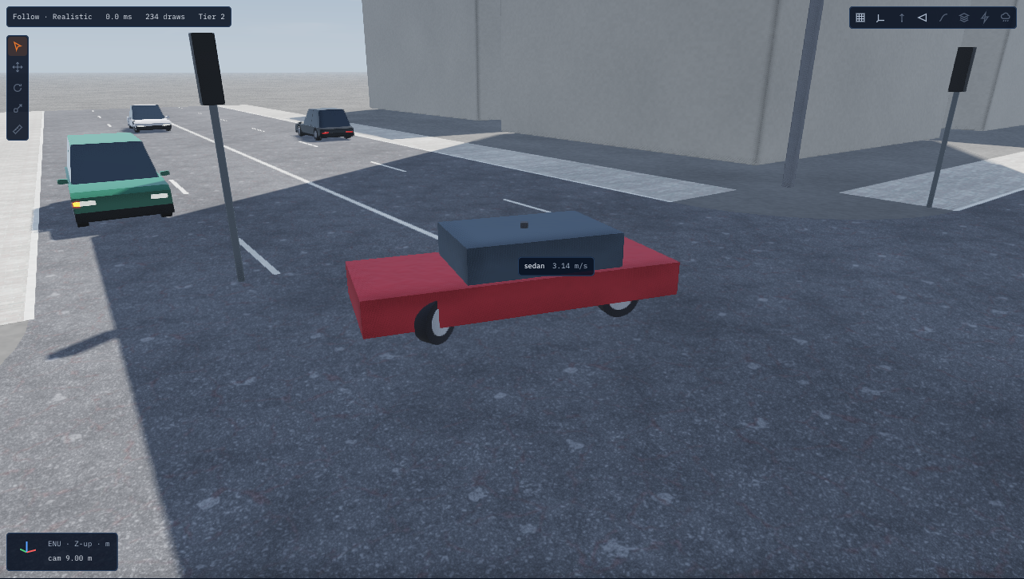
The sample sedan runs on vehicle dynamics: suspension, Magic Formula tyres, brakes, Ackermann steering and an electric or engine powertrain. It drives round the city block among traffic that follows its lanes and lights, has a radar and a camera, runs OpenSCENARIO scenarios, and takes Autoware’s commands.
lagrange sedan
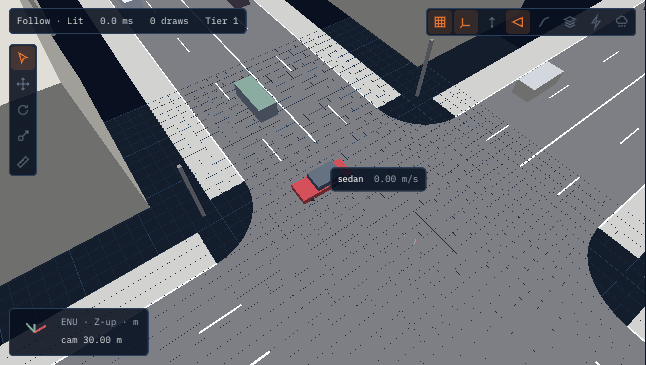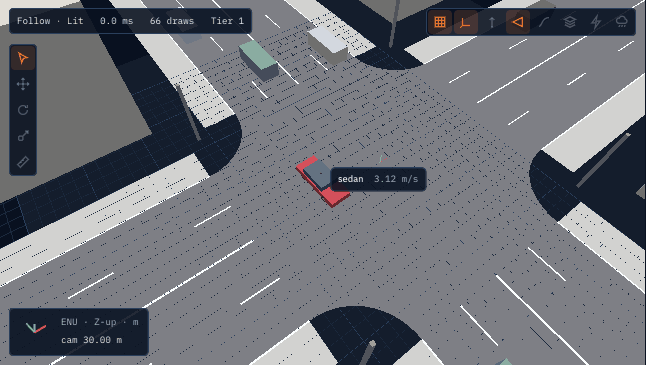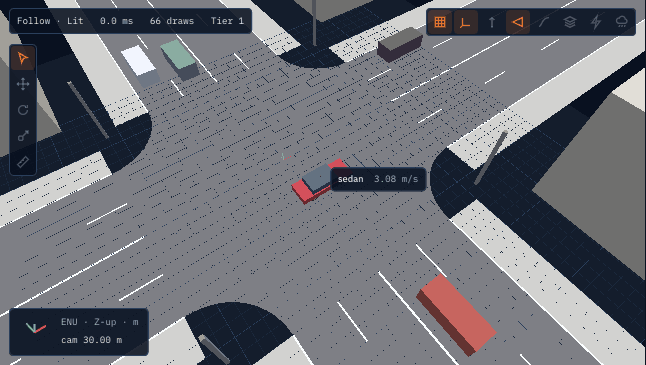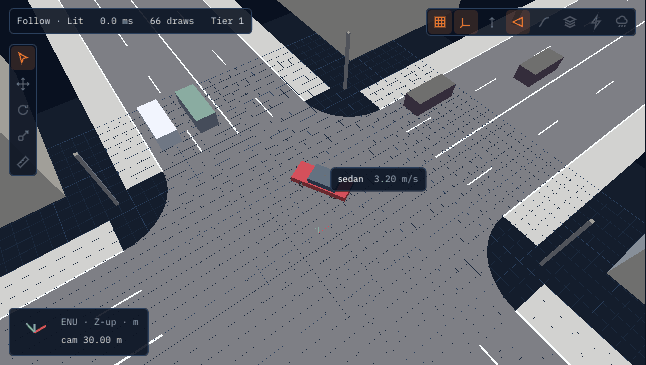
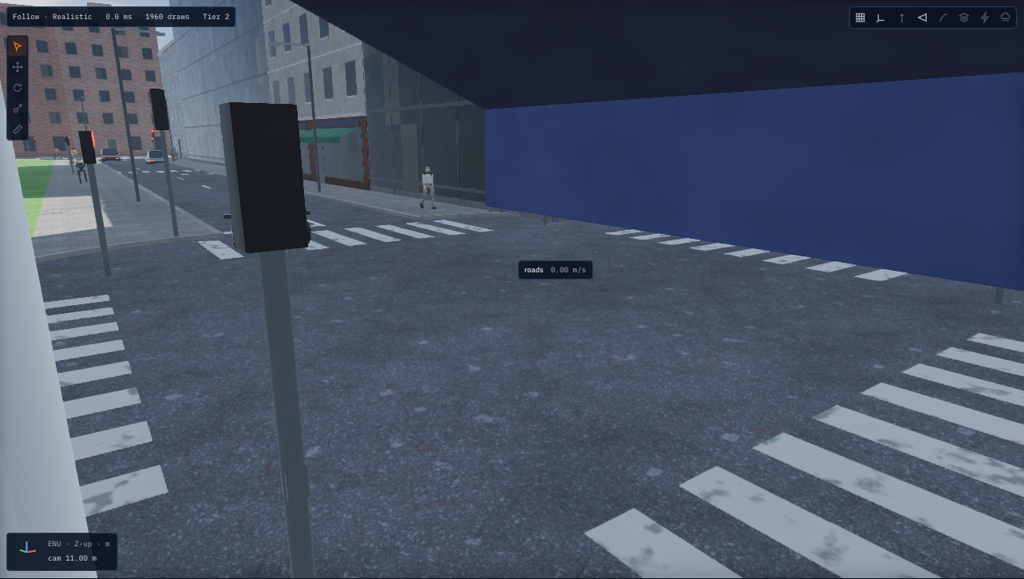
The town: working traffic lights, zebra crossings whose buttons people press, walking
people and self-driving cars. lagrange drive puts the sedan in it waiting for /cmd_vel.
lagrange town
The town: lights change, people press a button and cross, cars stop and go
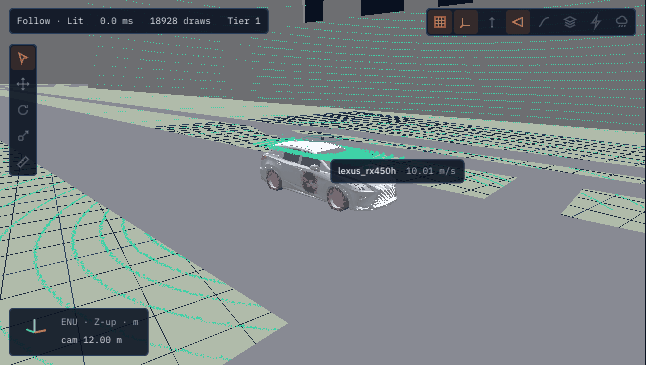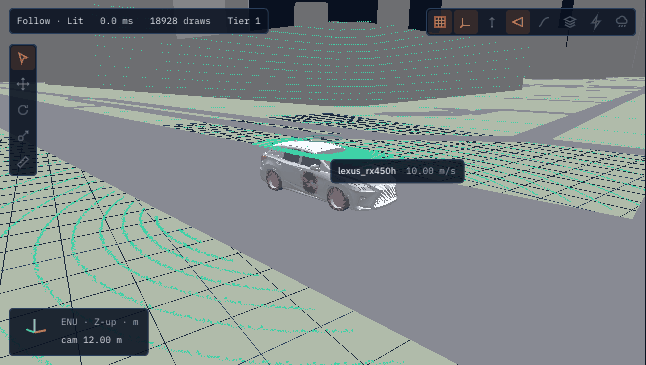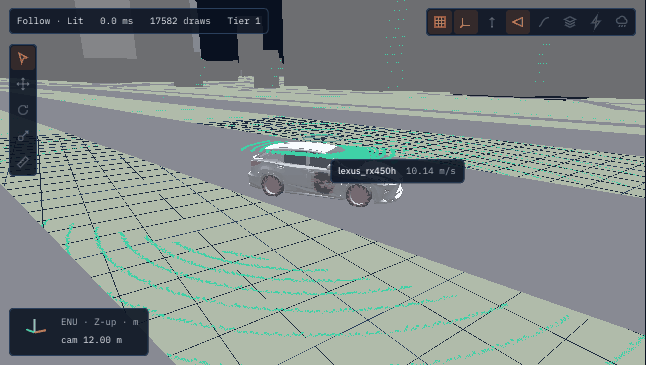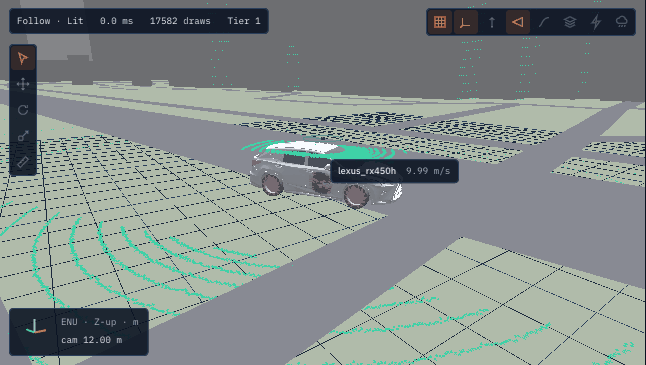
The Lexus RX 450h, Autoware’s sample vehicle, with its mesh and dimensions, here in Nishi-Shinjuku, Tokyo.
Tutorial: a car in a city block · Autoware · Vehicles · Traffic
Arms
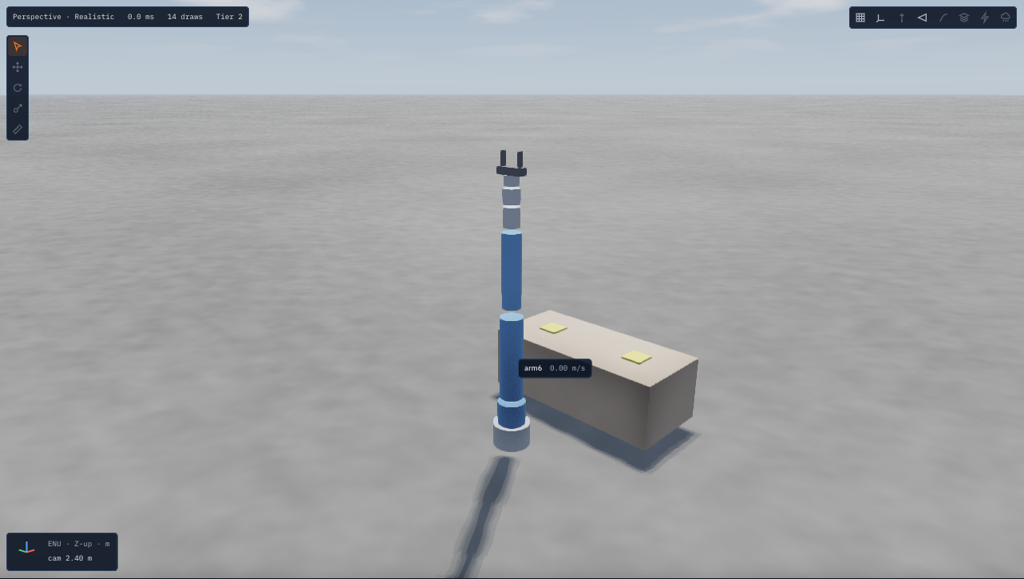
The sample 6-DoF arm on a 48 V bus, driven by MoveIt 2 through joint_trajectory_controller.
Its motors heat up, and an undersized set of motors derates and misses its moves.
ros2 launch lagrange_demos arm6_workcell.launch.py viewer:=true
An arm by position and by velocity per joint
Tutorial: the sample arm with MoveIt 2 · Thermal · Electrical network
Legged robots
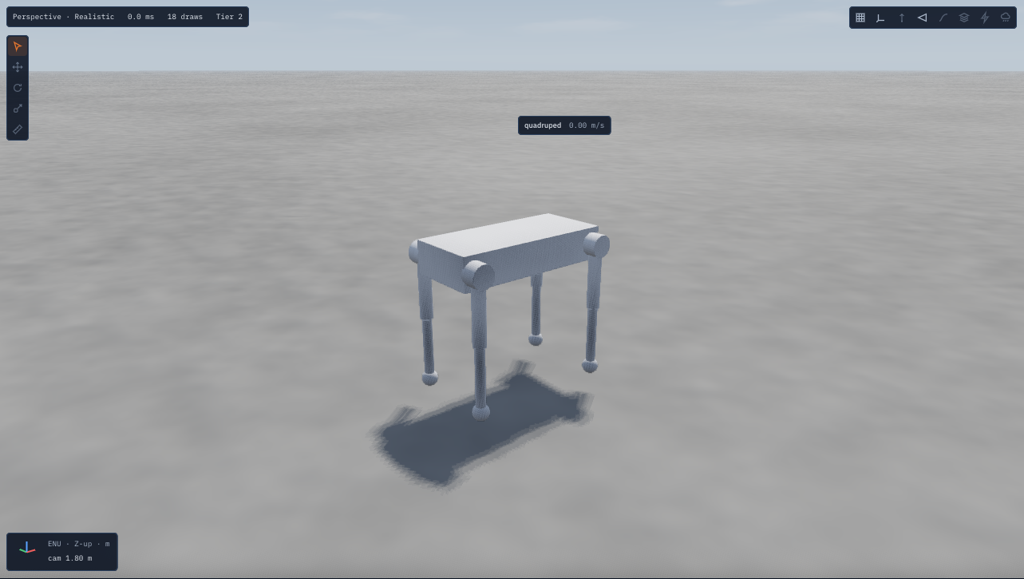
A quadruped settles into its stance and trots, joint by joint, from an ordinary ROS 2 node
(examples/lagrange_example_quadruped).
ros2 launch lagrange_example_quadruped trot.launch.py
On and under water
A wooden crate bobs at its draft, a steel one sinks
Bodies float, sink and drift in a current and in waves; a vehicle can carry its own Fossen added mass and damping, such as the BlueROV2 Heavy’s. Water.
Worlds
World |
What is in it |
Run it |
|---|---|---|
Sample warehouse |
Racks, pallets, walls |
|
AMR_FMS warehouse |
60 m × 40 m, docks |
|
Open field |
50 m field, a landing pad, trees, a shed |
|
Drone building |
A 12 m building to fly beside and over |
|
Power line |
A 400 A line next to a hovering drone |
|
City block |
OpenDRIVE roads, a junction, buildings, traffic |
|
Town |
Lights, crossings with buttons, people, cars |
|
Tiled town |
A world streamed in tiles round the robot |
|
Zurich, Tokyo |
Real places from open data, 40 km |
|
Pond |
Water for floating and sinking |
|
Workcell |
The arm’s table |
|
lagrange samples lists the samples. More clips are in the feature videos.